Peter Mortimer
I'm a PhD candidate at the Bundeswehr University in Munich. I'm interested in Machine Learning, Computer Vision, and Data Visualization.
Email · GitHub · Google Scholar · arXiv

Research
Here are all my publcations listed with links to the papers and repositories.
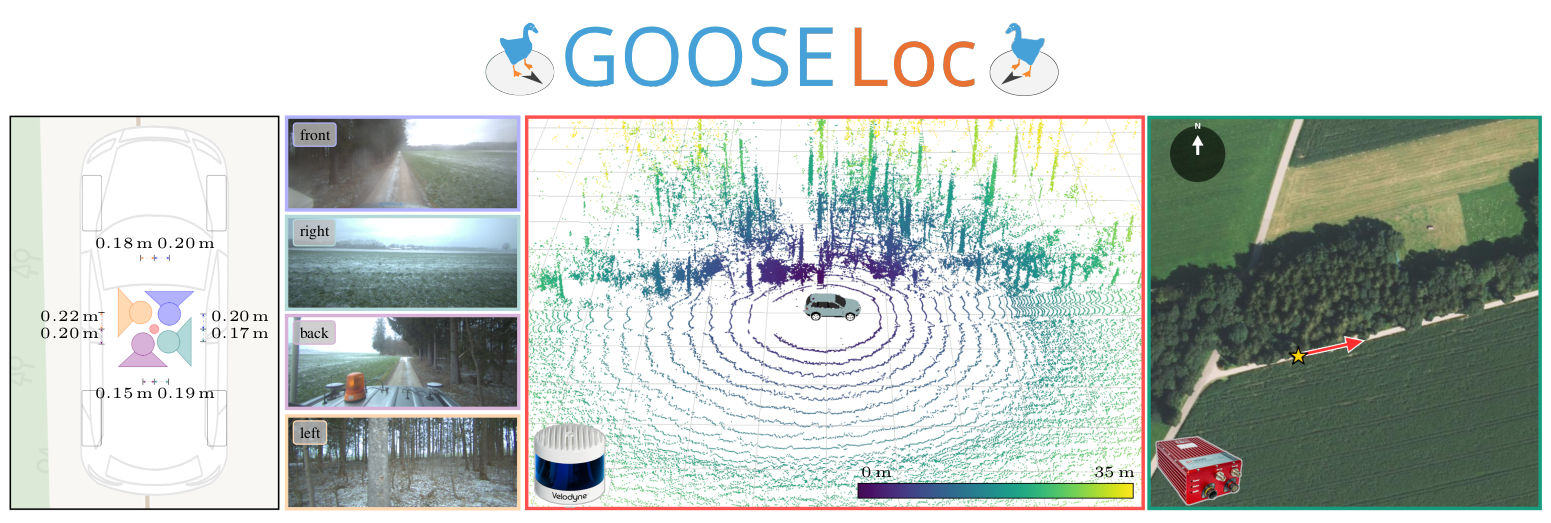
GOOSELoc: A Multimodal Benchmark for Ground-to-Aerial Localization in Unstructured Off-Road Terrain
Fabian Deuser, Peter Mortimer, Robin-Nico Kampa, Anna Boeßendoerfer, Mirko Maehlisch, Martin Werner, Norbert Oswalt
Winter Conference on Applications of Computer Vision (WACV), Orlando, USA, January 2027.

Surface-Aware Lane Departure for Obstacle Avoidance in Off-Road Environments Using Semantic Segmentation and MPC
Alexander Bienemann, Peter Mortimer, Thorsten Luettel, Mirko Maehlisch
International Conference on Intelligent Transportation Systems (ITSC), Gold Coast, Australia, November 2025.

Diffusion-Based Image Augmentation for Semantic Segmentation in Outdoor Robotics
Peter Mortimer, Mirko Maehlisch
Workshop on Field Robotics (W-FR @ ICRA), Atlanta, USA, May 2025.
Paper · Bibtex · Workshop Page

Excavating in the Wild: The GOOSE-Ex Dataset for Semantic Segmentation
Raphael Hagmanns, Peter Mortimer, Miguel Granero, Thorsten Luettel and Janko Petereit
International Conference on Robotics and Automation (ICRA), Atlanta, USA, May 2025.
Project Page · Paper · Bibtex

Survey on Datasets for Perception in Unstructured Outdoor Environments
Peter Mortimer and Mirko Maehlisch
Workshop on Field Robotics (W-FR @ ICRA), Yokohama, Japan, May 2024.
Paper · Bibtex · Workshop Page

The GOOSE Dataset for Perception in Unstructured Environments
Peter Mortimer, Raphael Hagmanns, Miguel Granero, Thorsten Luettel, Janko Petereit and Hans-Joachim Wuensche
International Conference on Robotics and Automation (ICRA), Yokohama, Japan, May 2024.
Project Page · Paper · Bibtex

How Do Vision Transformers See Depth in Single Images?
Peter Mortimer and Hans-Joachim Wuensche
Workshop on Scene Representations for Autonomous Driving (SR4AD @ ICLR), Kigali, Ruwanda, May 2023.

TAS-NIR: A VIS+NIR Dataset for Fine-grained Semantic Segmentation in Unstructured Outdoor Environments
Peter Mortimer and Hans-Joachim Wuensche
Workshop on Planning, Perception and Navigation for Intelligent Vehicles (PPNIV @ IROS), Kyoto, Japan, October 2022.
Project Page · Paper · Dataset · Bibtex

A Fine-Grained Dataset and its Efficient Semantic Segmentation for Unstructured Driving Scenarios
Kai Andreas Metzger, Peter Mortimer and Hans-Joachim Wuensche
International Conference on Pattern Recognition (ICPR), Milan, Italy, January 2021.
Project Page · Paper · Dataset · Video · Bibtex
Talks
Here are all my talks that are publicly available.
Einsatz von camera_aravis2 zur Kamerakonfiguration auf Robotersystemen (🇩🇪)
ROSCon DE 2024, Karlsruhe, Germany.

20/20 Robot Vision - How to setup cameras in ROS 1 & ROS 2 using camera_aravis
ROSCon 2022, Kyoto, Japan.

Media Appearances
Here are all appearances of my work in public media.
